About Me

I am a Ph.D. student at Huazhong University of Science and Technology (HUST), advised by Prof. Qinbin Li. I received my B.Eng. degree from HUST in 2026.

My research focuses on large language model systems and efficient agent frameworks. I am also exploring AI for Science (AI4S), particularly proteins and drug discovery, and welcome collaboration opportunities in this area.
News
Sep 2026 One paper accepted to ATC 2026. See you in Hong Kong!
Sep 2026 Started my Ph.D. at HUST.
Dec 2025 Invited to present our work "AutoTool" at the 37th MLNLP Academic Seminar (Meetup) Link Slide
Nov 2025 One paper accepted to AAAI 2026.
Research
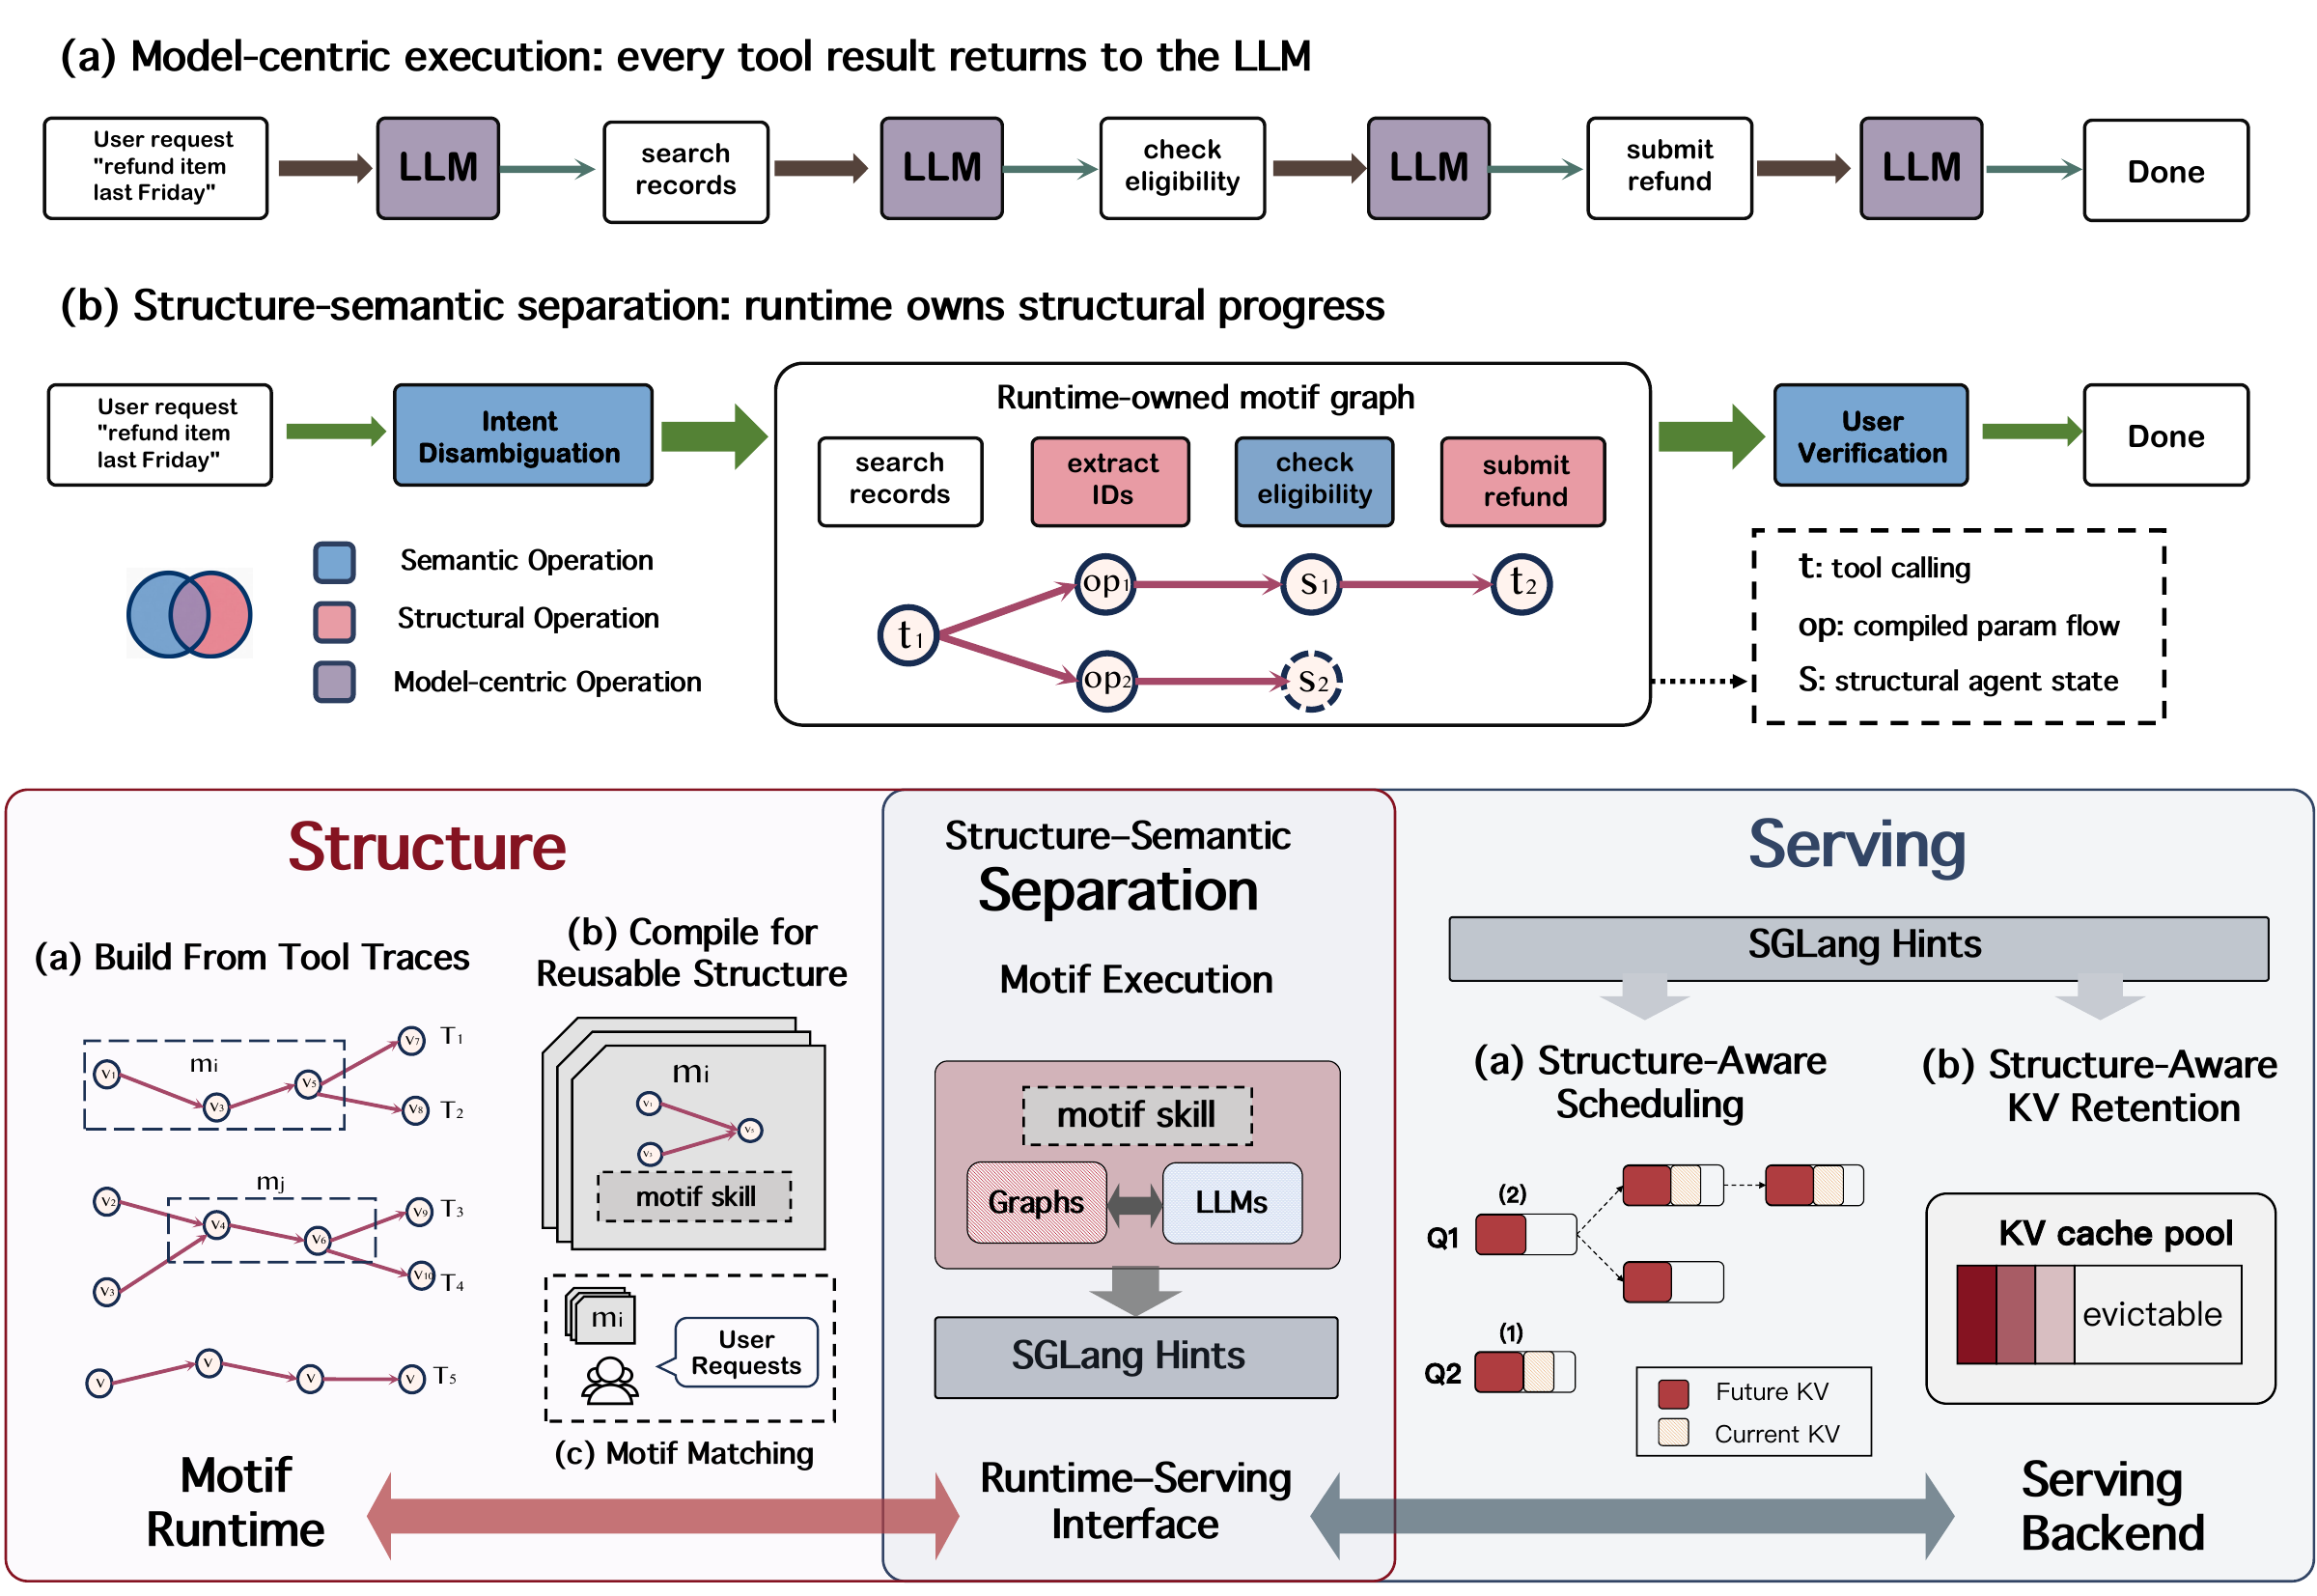
Make Graphs Great Again: Rethinking LLM Agent Architecture via Structure-Semantic Separation
Jingyi Jia, Jiale Wang, Haoyi Zhang, Qinbin Li*, Xiaofei Liao, Hai Jin
ACM SIGOPS ATC, 2026

Motivation Can structure-semantic separation break the monolithic LLM agent loop by moving verifiable execution into the runtime?

Contribution MotifAgent uses executable motif graphs for structure-semantic separation: structural operations execute verified tool flows, semi-structural operations mediate missing information within graph constraints, and semantic operations resolve ambiguity with the LLM. Motif progress also guides scheduling and KV-cache retention.

Paper Teaser
AutoTool: Efficient Tool Selection for Large Language Model Agents
Jingyi Jia, Qinbin Li*
AAAI, 2026 Paper GitHub

Motivation Can we utilize statistical methods instead of relying heavily on LLM inference to select tools efficiently?

Contribution We propose AutoTool, which actively manages tool usage inertia via a Tool Inertia Graph. By selectively bypassing LLM inference, it reduces token consumption by up to 30% while maintaining competitive performance.

Honors
2026
CCF Elite Collegiate Award
Outstanding Graduate of HUST
Hisense Scholarship
2025
Tencent Scholarship
Selected Projects
Virtual Kernel Framework for Containers
Implemented independent task scheduling within containers utilizing Linux cgroup and namespace mechanisms. Linux Kernel · Virtualization
RoboMaster Radar Station Maintenance
Participated in the RoboMaster University Championship. Calibrated radar extrinsics and camera intrinsics, and trained YOLO models for real-time detection. Computer Vision · Robotics
Personal
Denken · Warten · Fasten
Philosophy
Cinema
Seal Carving
Outdoor Adventure